The world of robotics is an ever-evolving landscape, and one of the key challenges in creating lifelike, dynamic machines is the development of efficient actuators. [Food for Robots] has taken on this challenge head-on, and their journey provides an insightful glimpse into the complexities of building a walking robot.
The Actuator Conundrum
When it comes to designing a walking robot, one of the biggest hurdles is finding a suitable actuator. Unlike biological systems with their flexible muscles, robots lack the same level of compact, powerful linear actuators. This is a significant drawback, especially for robots aiming to mimic human or animal locomotion.
[Food for Robots]' project is an attempt to bridge this gap, and their approach is an intriguing blend of engineering and innovation.
Iteration and Innovation
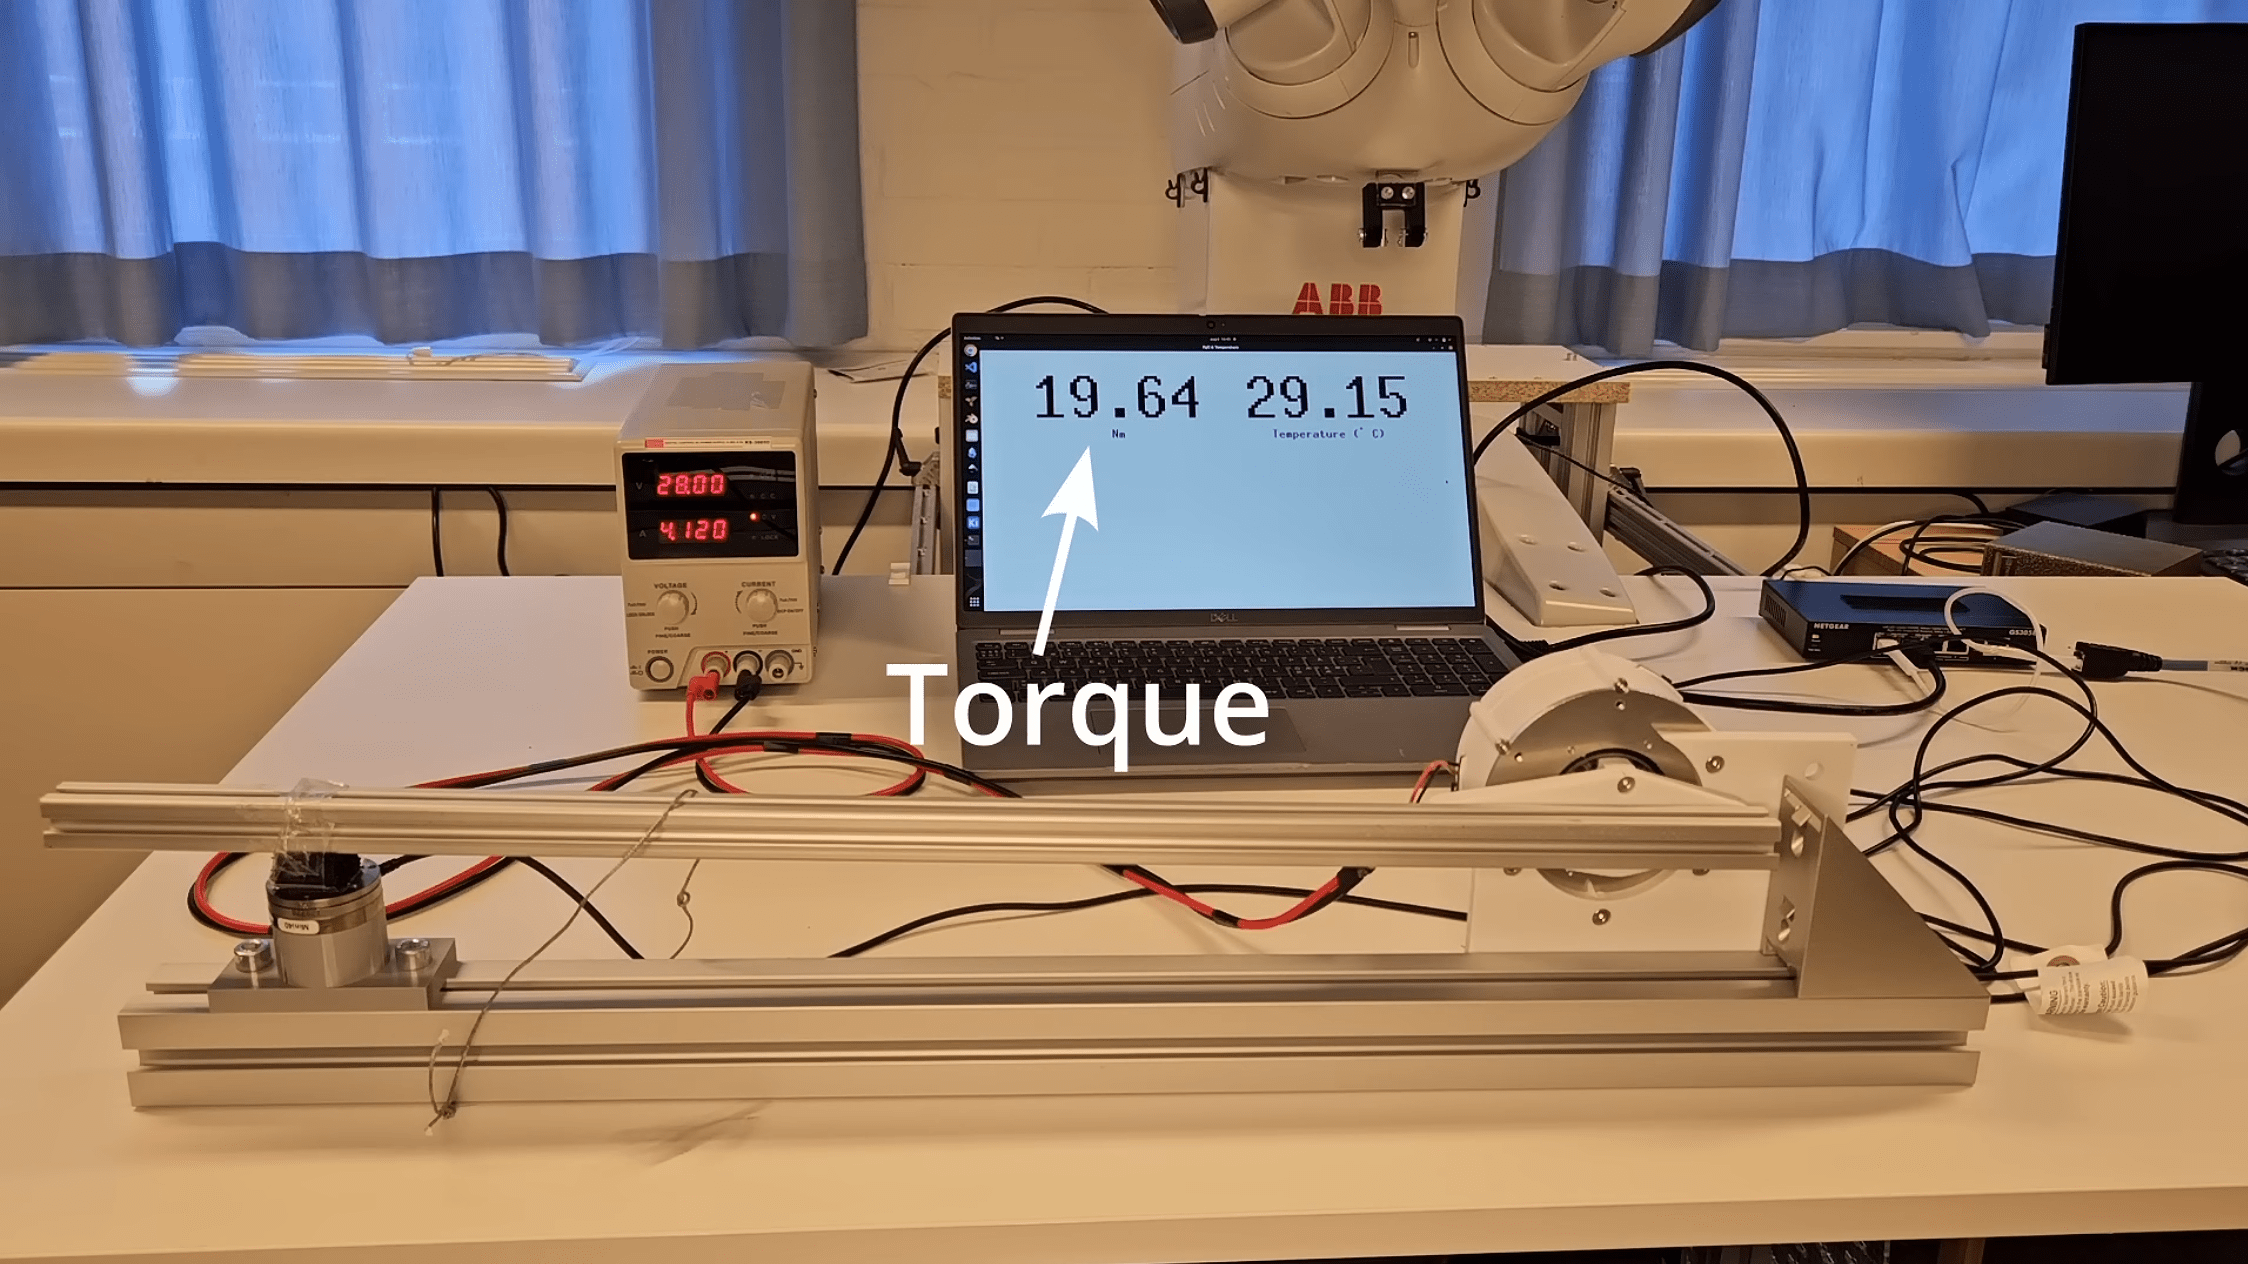
The first prototype, largely 3D-printed, faced limitations when it came to torque. Parts broke under the strain of exceeding 10 Nm, highlighting the need for a more robust design. The second iteration saw a shift to aluminum, a material that offered greater strength and durability.
What makes this particularly fascinating is the problem-solving nature of the project. [Food for Robots] didn't just accept the limitations of their initial design; they investigated, adapted, and improved. This iterative process is a hallmark of successful engineering, and it's a joy to see it in action.
The Gearbox Advantage
By switching to a planetary gearbox, [Food for Robots] was able to increase the strength of the actuator while keeping its size compact. This is a clever use of existing technology, and it shows how small modifications can lead to significant improvements.
The gearbox, nestled within the stator, is a key component. Its multi-layered gear system provides the necessary power boost, allowing the actuator to reach the desired torque levels.
Control and Optimization
The control system is another critical aspect. By using a small magnet on the motor's rotor and a custom control board, [Food for Robots] achieved precise position reading. This level of control is essential for a walking robot, as it allows for smooth, accurate movements.
In my opinion, this is where the project really shines. The combination of mechanical innovation and precise control is a testament to the builder's skill and vision.
Looking Forward
The world of robotics is full of exciting possibilities, and projects like this showcase the potential for innovation. While [Food for Robots]' actuator is a significant step forward, it also raises new questions and challenges.
As we continue to push the boundaries of robotics, we must ask: How can we further optimize these designs? What other materials or technologies could be explored to enhance performance?
The journey of building a walking robot is a long and complex one, but projects like this inspire and motivate. They remind us of the incredible potential that lies within the fusion of engineering, creativity, and a passion for robotics.